
2026 International Conference on Machine Learning and Unmanned Systems (MLUS 2026) Successfully Concluded
On May 30, 2026, the 2026 International Conference on Machine Learning and Unmanned Systems (MLUS 2026) was successfully held online via Zoom. The conference focused on cutting-edge fields including machine learning, unmanned systems, intelligent control, and data-driven optimization, featuring a series of keynote speeches and oral presentation sessions with a rich agenda and a vibrant academic atmosphere.
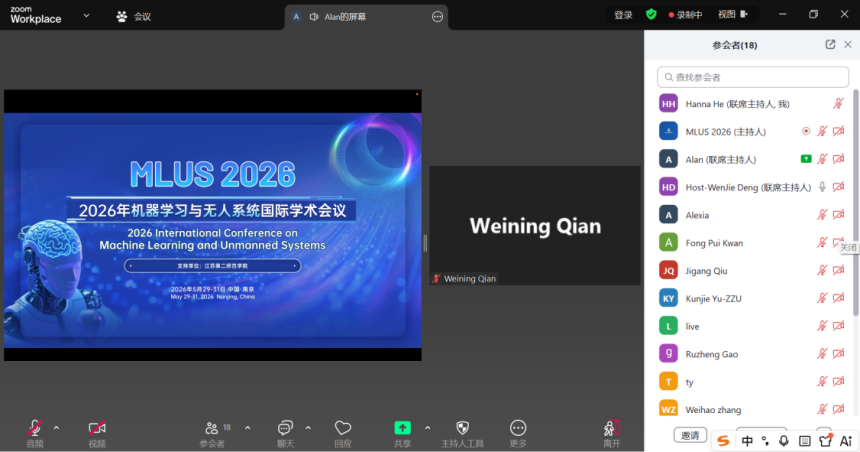
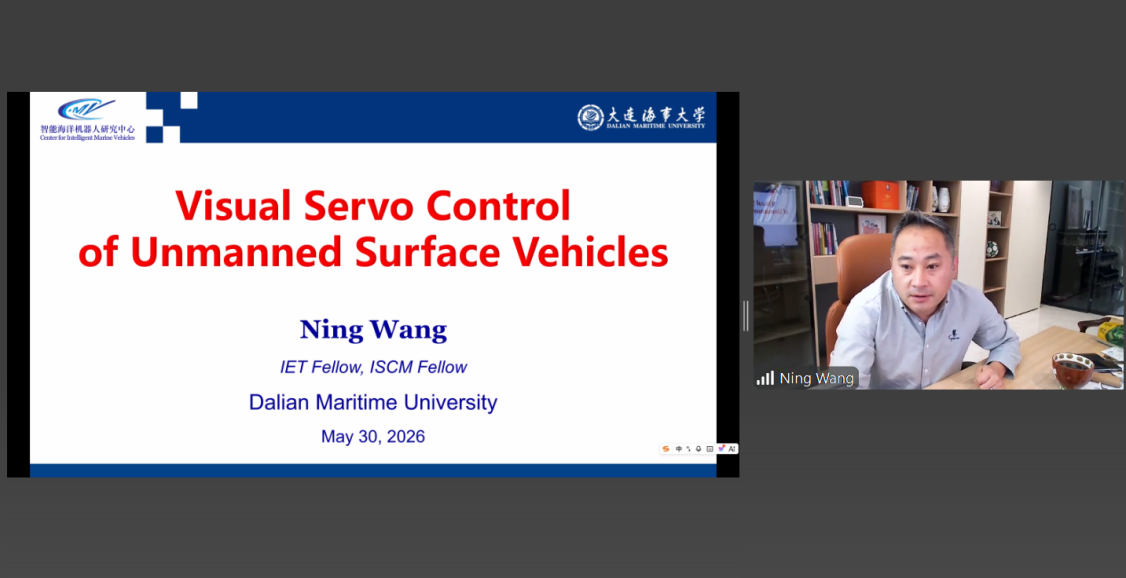
The conference centered on core topics such as visual servoing for embodied-intelligence marine vehicles, data-driven optimal control under an event-triggered framework, and optimization decision-making methods under complex constraints based on knowledge learning. Three distinguished keynote speakers were specially invited: Prof. Ning Wang (IET/IMarEST/IIAV/ISCM Fellow) from Dalian Maritime University, China; Prof. Mouquan Shen from Nanjing Tech University, China; and Prof. Kunjie Yu (IEEE Member) from Zhengzhou University, China. The presentations were insightful and forward-looking, sparking lively discussions and exchanges among participants.
The first Plenary speaker is Prof. Ning Wang, from Dalian Maritime University, China His Speech title is: Visual Servoing for Embodied-Intelligence Marine Vehicles |
Following this speech, the next Plenary speaker is Prof. Mouquan Shen, from Nanjing Tech University, China His Speech title is:Data-driven optimal control under event-triggered framework |
Last, the speaker is, IEEE Member, Zhengzhou University, China His Speech title is:Optimization Decision-Making Methods and Applications under Complex Constraints Based on Knowledge Learning |


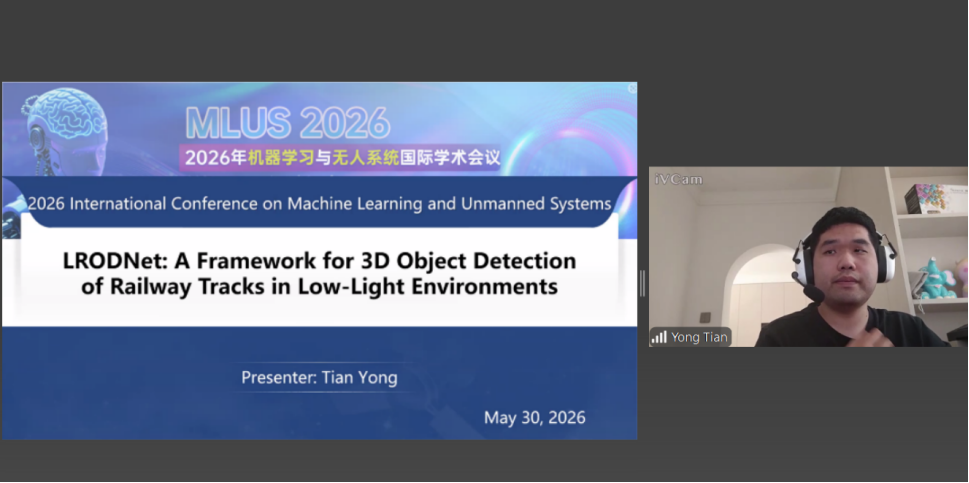
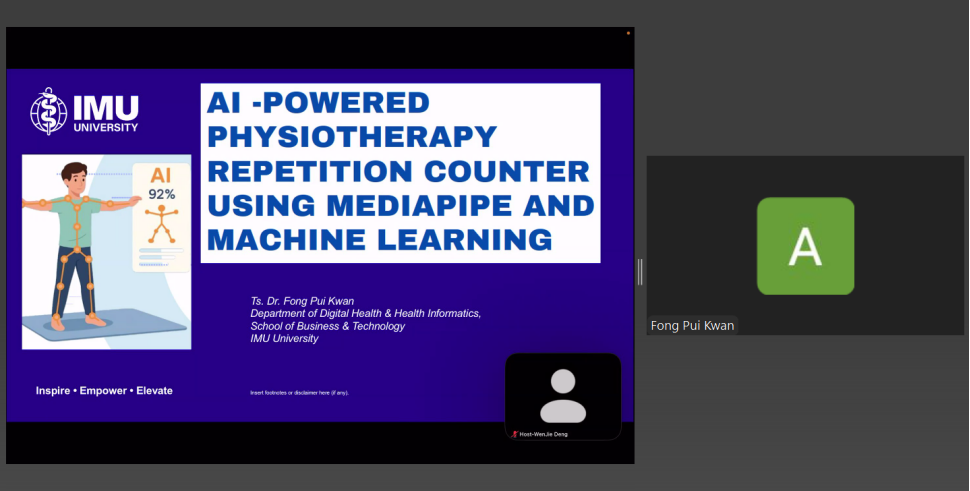
In the oral presentation sessions, young scholars from Changchun University of Science and Technology (China), IMU University (Malaysia), Nanjing Marine Radar Research Institute (China), National University (Philippines), and Nanjing Tech University (China) presented their latest research findings. Topics included LRODNet: a framework for 3D object detection of railway tracks in low-light environments, an AI-powered physiotherapy exercise classification system using MediaPipe and machine learning, design and implementation of an intent-routed lightweight LLM radar agent system, parameter-efficient small object detection via P2 head co-design for UAV remote sensing images, data-driven fault-tolerant control via dual pseudo-partial derivatives and neural approximation, and fixed-time synchronization control of disturbed complex networks via an observer approach. These presentations fully demonstrated the broad prospects of machine learning and unmanned systems technologies across multiple application domains.
Yong Tian, from Changchun University of Science and Technology, China |
Fong Pui Kwan, from IMU University, Malaysia |
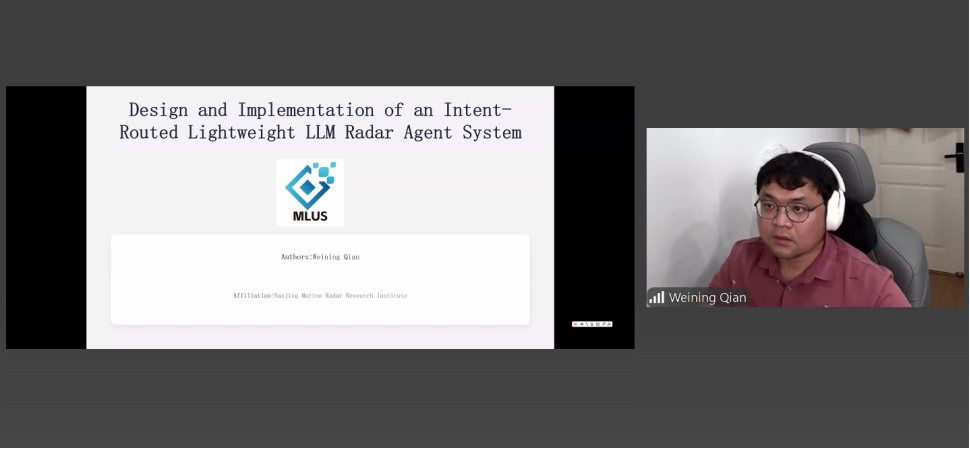
Weining Qian, from Nanjing Marine Radar Research Institute, China |
Gao Ruzheng, from National University (Philippines), Philippines |
Weihao Zhang, from Nanjing Tech University, China |
Jigang Qiu, from Nanjing Tech University, China |


The successful organization of this conference would not have been possible without the dedicated efforts and close collaboration of all participating experts, scholars, and staff members. Our sincere gratitude goes to all presenters, participants, and volunteers for their support and involvement! MLUS 2026 has built a productive platform for academic exchange and collaborative innovation in the fields of machine learning and unmanned systems. We look forward to reuniting with all colleagues at future conferences to jointly promote disciplinary development and technological progress.